← Hobby builds

Hobby build — 2023 – 2024

Rebuilding the InMoov robot hand

2023 – 2024Personal project3D printingReplication

What happens when someone who just finished a dissertation on prosthetic hands gets a 3D printer: an open-source robot hand, printed and assembled piece by piece.

FIG. 01 — IT MOVES

01 — The story

Why rebuild someone else’s hand?

Finishing my BEng dissertation on a modified prosthetic hand didn’t end my interest in hands. Between 2023 and 2024, with a 3D printer newly on my desk, I kept researching hand prosthetics by rebuilding one of the best-known open-source robot hands: the hand of the InMoov robot.

InMoov is an open-source, life-size, 3D-printable humanoid robot, started in January 2012 by French sculptor and designer Gaël Langevin, who shares the parts so anyone can print and build one. Its hand works much like ours: servo motors in the forearm pull on braided fishing-line “tendons” that curl each finger, while springs keep the tendons under tension.

Printing and assembling a proven design was my way of seeing how a working hand comes together, from how the tendons are routed through each finger to how the servos pull them, and of comparing it with the hand I had built for my dissertation.
Where it started: my BEng prosthetic hand →
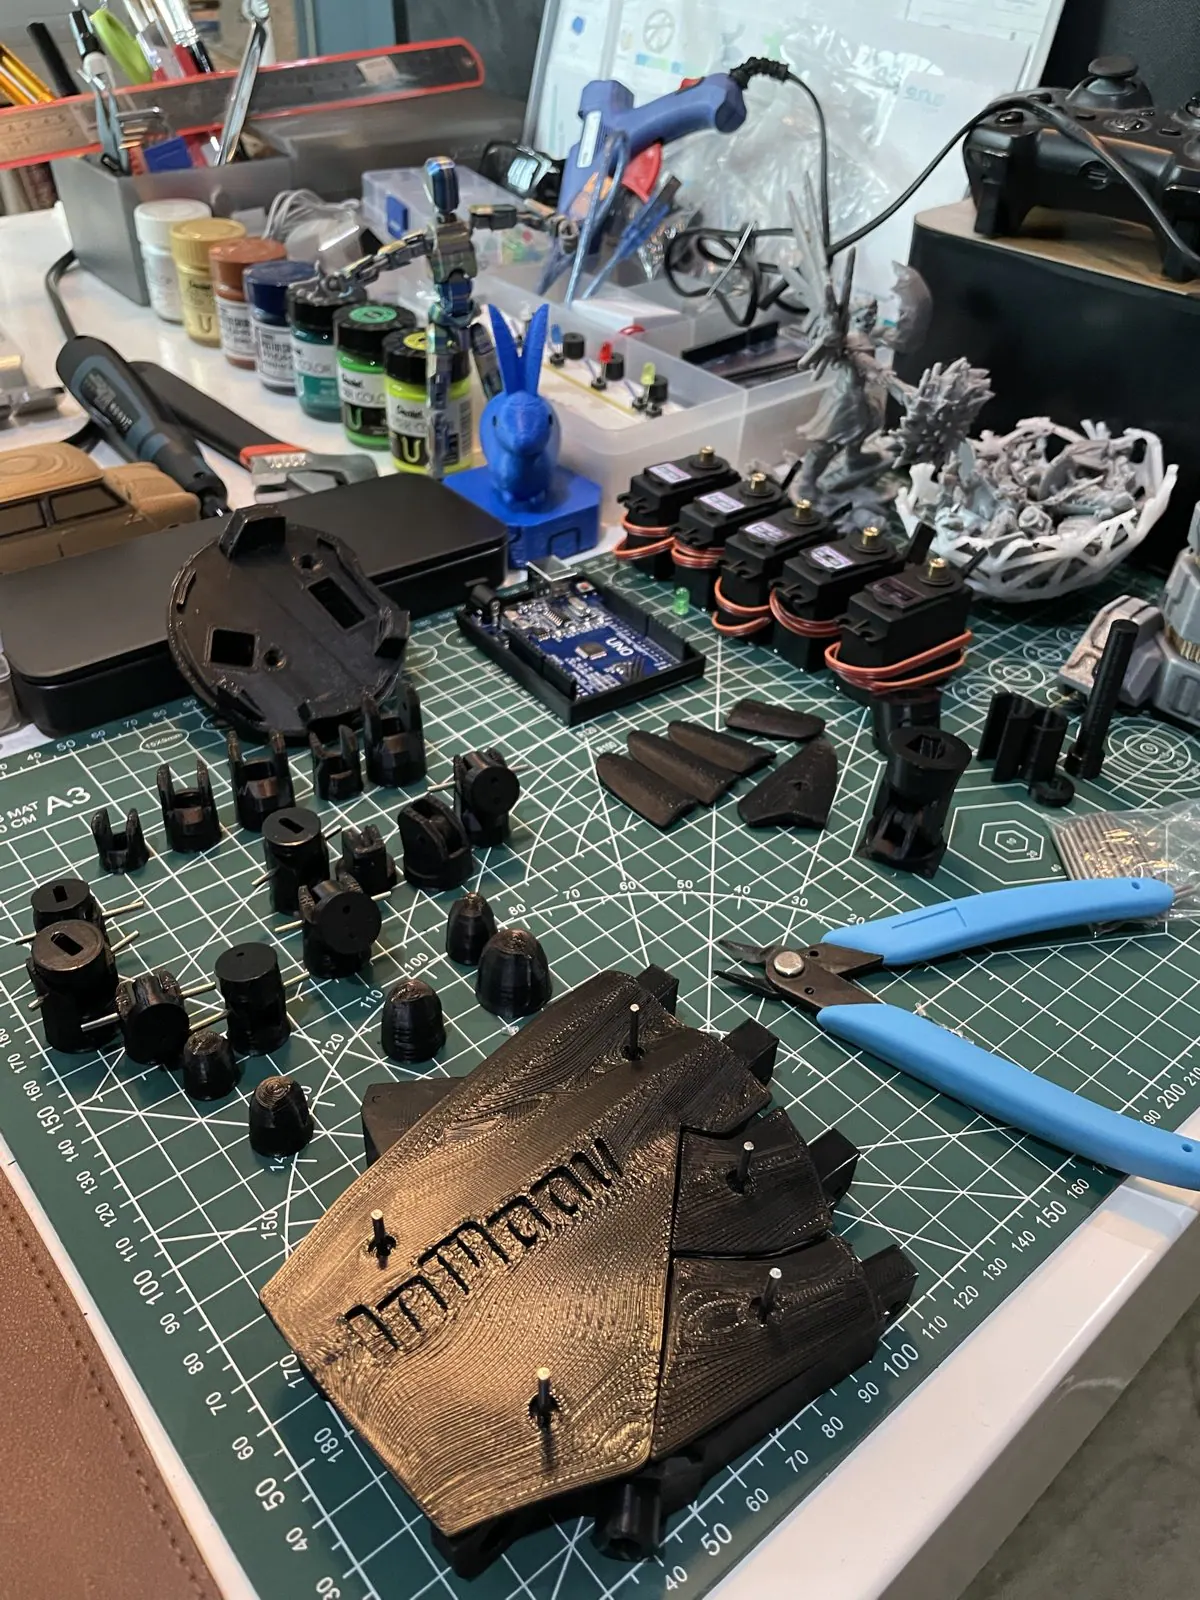
Printed black InMoov hand parts laid out on a cutting mat: finger segments, fingertips, palm covers with the InMoov logo, five servos and an Arduino Uno
EVERYTHING LAID OUT: FINGER SEGMENTS, PALM COVERS (ONE WITH THE INMOOV LOGO), FIVE SERVOS AND AN ARDUINO UNO.
InMoov — open source 3D printed life-size robot

Credit where it’s due

I did not design this hand. The InMoov hand is Gaël Langevin’s work; I printed and assembled it purely out of curiosity and as a hobby after getting my 3D printer.
Black-and-white portrait of Gaël Langevin, creator of InMoov
PHOTO: Y. LANGEVIN

Shoutout

Gaël Langevin, creator of InMoov

To Gaël and the InMoov community, for keeping the designs open. It’s exactly the kind of project that turns a new 3D printer into a classroom.

Visit inmoov.fr ↗

The build diary

From the first print to the first movement
Every clip loops on its own, in build order

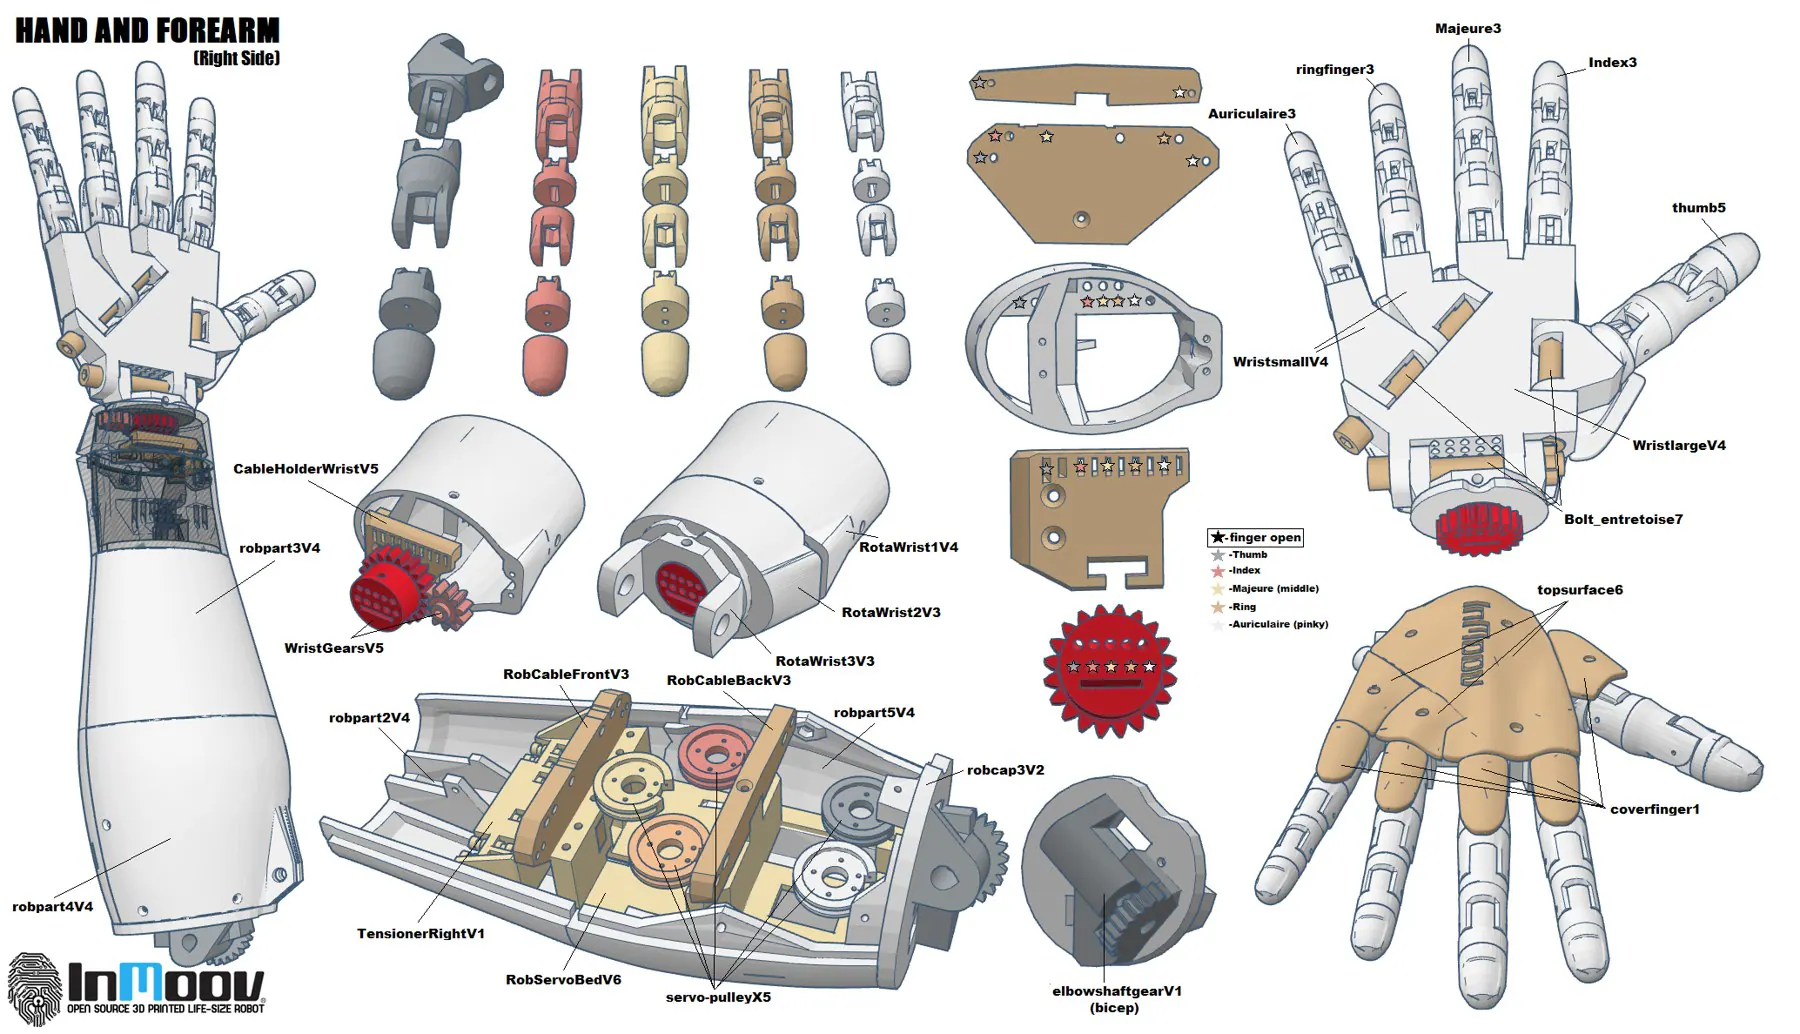
InMoov hand and forearm parts guide, showing every printed part labelled, from finger segments to the servo bed and wrist gears
THE MAP I FOLLOWED: INMOOV’S HAND-AND-FOREARM PARTS GUIDE. IMAGE: INMOOV / GAËL LANGEVIN.
01The first layersThe printer laying down the first hand parts in black filament. Every finger of the InMoov hand is printed as several small pieces, so this is where it all begins.
02A bed full of knucklesA whole plate of finger joints printing at once. Each finger is a chain of small hinged segments, joined later with metal pins.
03The palm takes shapeBigger, flatter parts next: the palm and the covers for the back of the hand, one of which carries the InMoov logo.
5× speed
04Harvest dayPeeling a finished batch off the flexible print bed and laying the parts out on the mat, ready to sort.
05Forearm shellA large forearm shell coming off the bed. The forearm is where the hand’s “muscles” live: the servos that pull the tendons.
2× speed
06Screwdriver timeFastening the parts together, starting with the servo bed that sits inside the forearm.
07Round parts, slow printsA ring-shaped forearm piece on the printer. The larger parts are the slowest to print, so patience became part of the project.
2× speed
08Five servos, five tendonsThe forearm opened up: five servos with pulleys, one for each finger, wired up and ready to be tested.
2× speed
09Does it bend?Checking a finger by hand, making sure every joint swings freely before the tendons go in.
2.5× speed
10Late-night assemblyEvenings at the desk under the lamp, fitting the fingers and fine-tuning the hand.
11It movesThe assembled hand on the desk, fingers curling on command from code running on the laptop. The moment it all came together.

Discussion

Comments

No comments yet

Register with your email to join the discussion

Your email is never shown publicly.

No comments yet. Be the first to share your thoughts.